Projects

2nd Place International ERC Drone Task: Fully Autonomous UAV for Vision-Based Sample Localization & Precision Landing
Robotics
2025-10 to 2026-09

2nd Place International ERC Drone Task: Fully Autonomous UAV for Vision-Based Sample Localization & Precision Landing

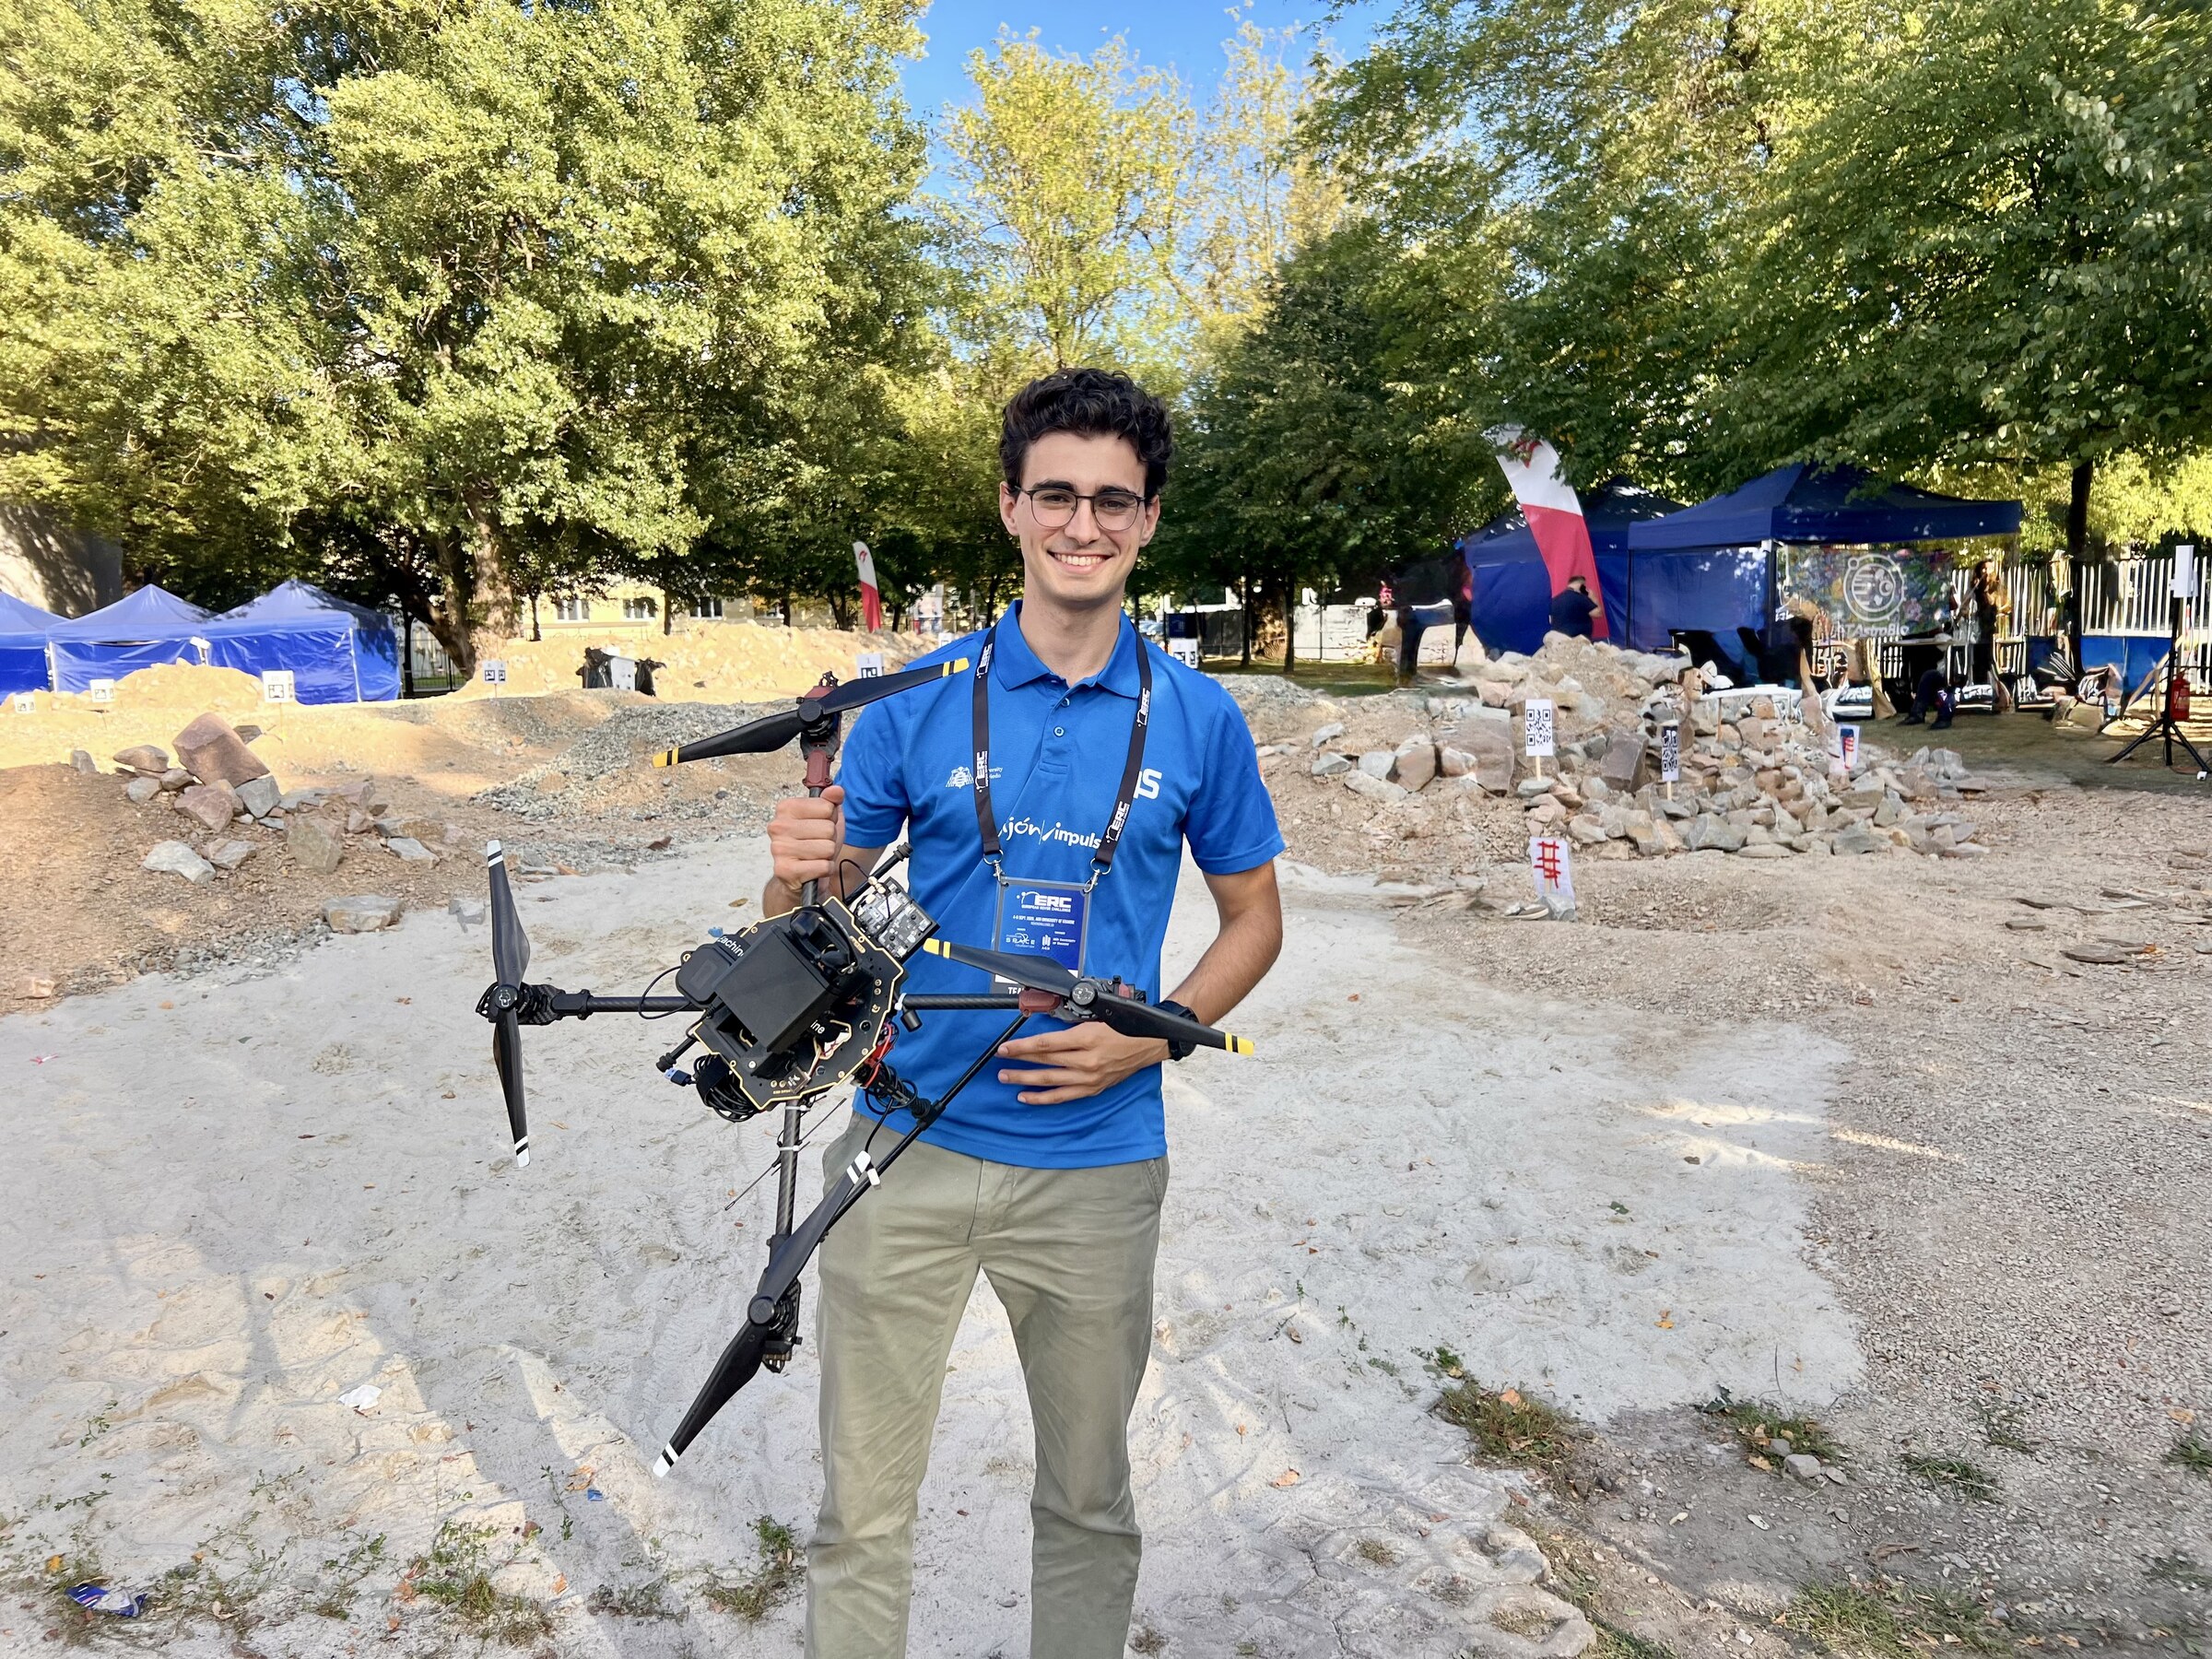
International placeERC drone task · 295/300 points

2nd place internationally in the ERC drone-task scoring with 295/300 points, behind EPFL Xplore and tied with Brno Mars Rover, without GPS or GNSS: LiDAR, an optical-flow sensor and a Raspberry Pi 5 running the real-time CNN perception and MAVLink autonomous flight software I designed and implemented onboard.

  • Three consecutive autonomous flights over the drone Mars Yard.
  • 8/9 sample tubes detected and localized with ground-position accuracy below 10 cm.
Raspberry Pi 5Optical flowLiDARCNNMATLAB / MATLAB CoderC++MAVLinkGazebo / ArduPilot SITL
View project
Landsat Connect: A NASA Space Apps “Best Mission Concept” Winner
Personal
2024

Landsat Connect: A NASA Space Apps “Best Mission Concept” Winner

Global WinnerNASA Space Apps Challenge 2024 · 93,520 participants worldwide

Web app concept to track Landsat passes and access Landsat Surface Reflectance data with notifications.

  • Designed an accessibility-first workflow for Landsat overpass notifications and SR data access.
View project
Design and Implementation of the Software Architecture of a Space Rover for the ERC 2025
Research
2024 to 2025

Design and Implementation of the Software Architecture of a Space Rover for the ERC 2025

Qualification phaseERC 2025 · out of 102 teams

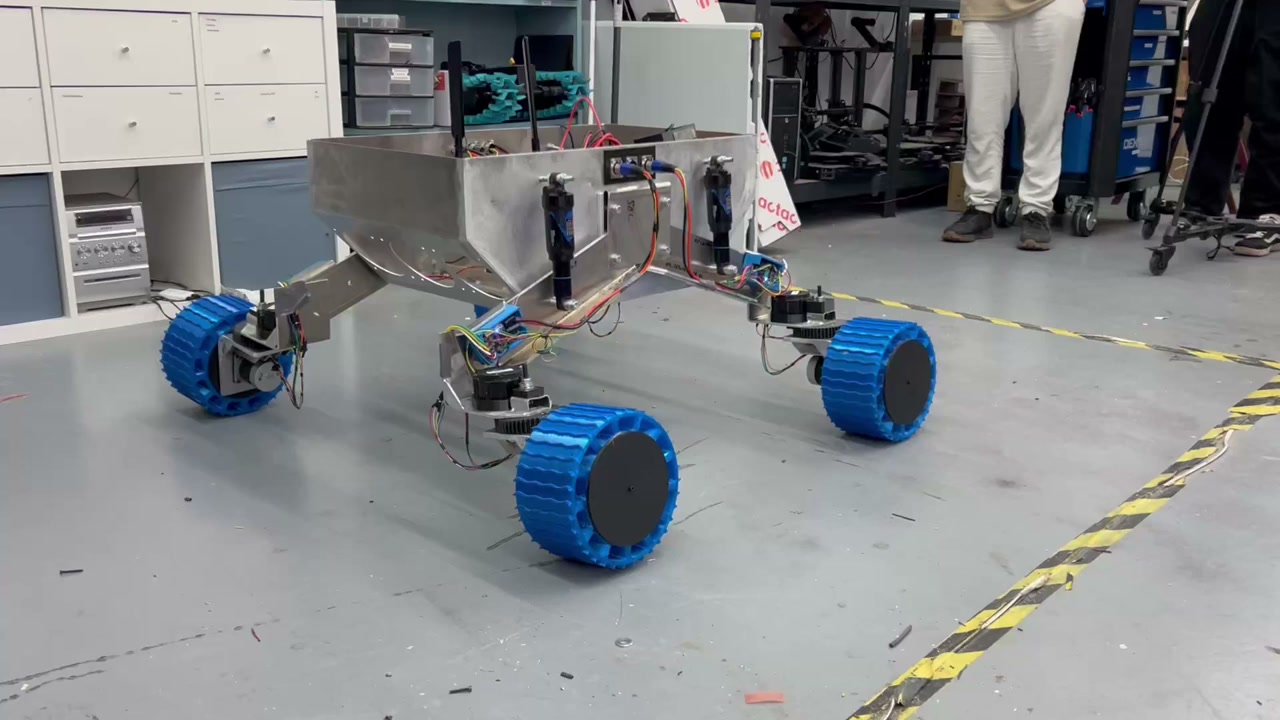
Software-led rover development across the ERC 2024-2025 cycle: from early wooden drivetrain prototypes to the aluminium rover with arm, gripper, drill, and field validation. My role focused on the software architecture, motion control, subsystem sequencing, and integration work that helped the team finish 3rd out of 102 teams in the ERC 2025 qualification phase and reach the final in Kraków.

  • Software lead for drivetrain control, motion primitives, manipulator sequencing, and integration validation.
  • Distributed architecture across platform, arm, drill, and ground station with ROS 2 nodes and CAN-connected subsystems.
  • Control stack matured from a misaligned wooden prototype to an aluminium rover with load-aware drive tests.
C++PythonROS 2CAN bus integrationWiMAX rover-ground-station linkEmbedded rover controlMotion-state sequencingManipulator integrationField-test validation
View project
A 3D-Printed Autonomous Lawn Mower (From Zero to Cutting Grass)
Personal
2024-12 to Present

A 3D-Printed Autonomous Lawn Mower (From Zero to Cutting Grass)

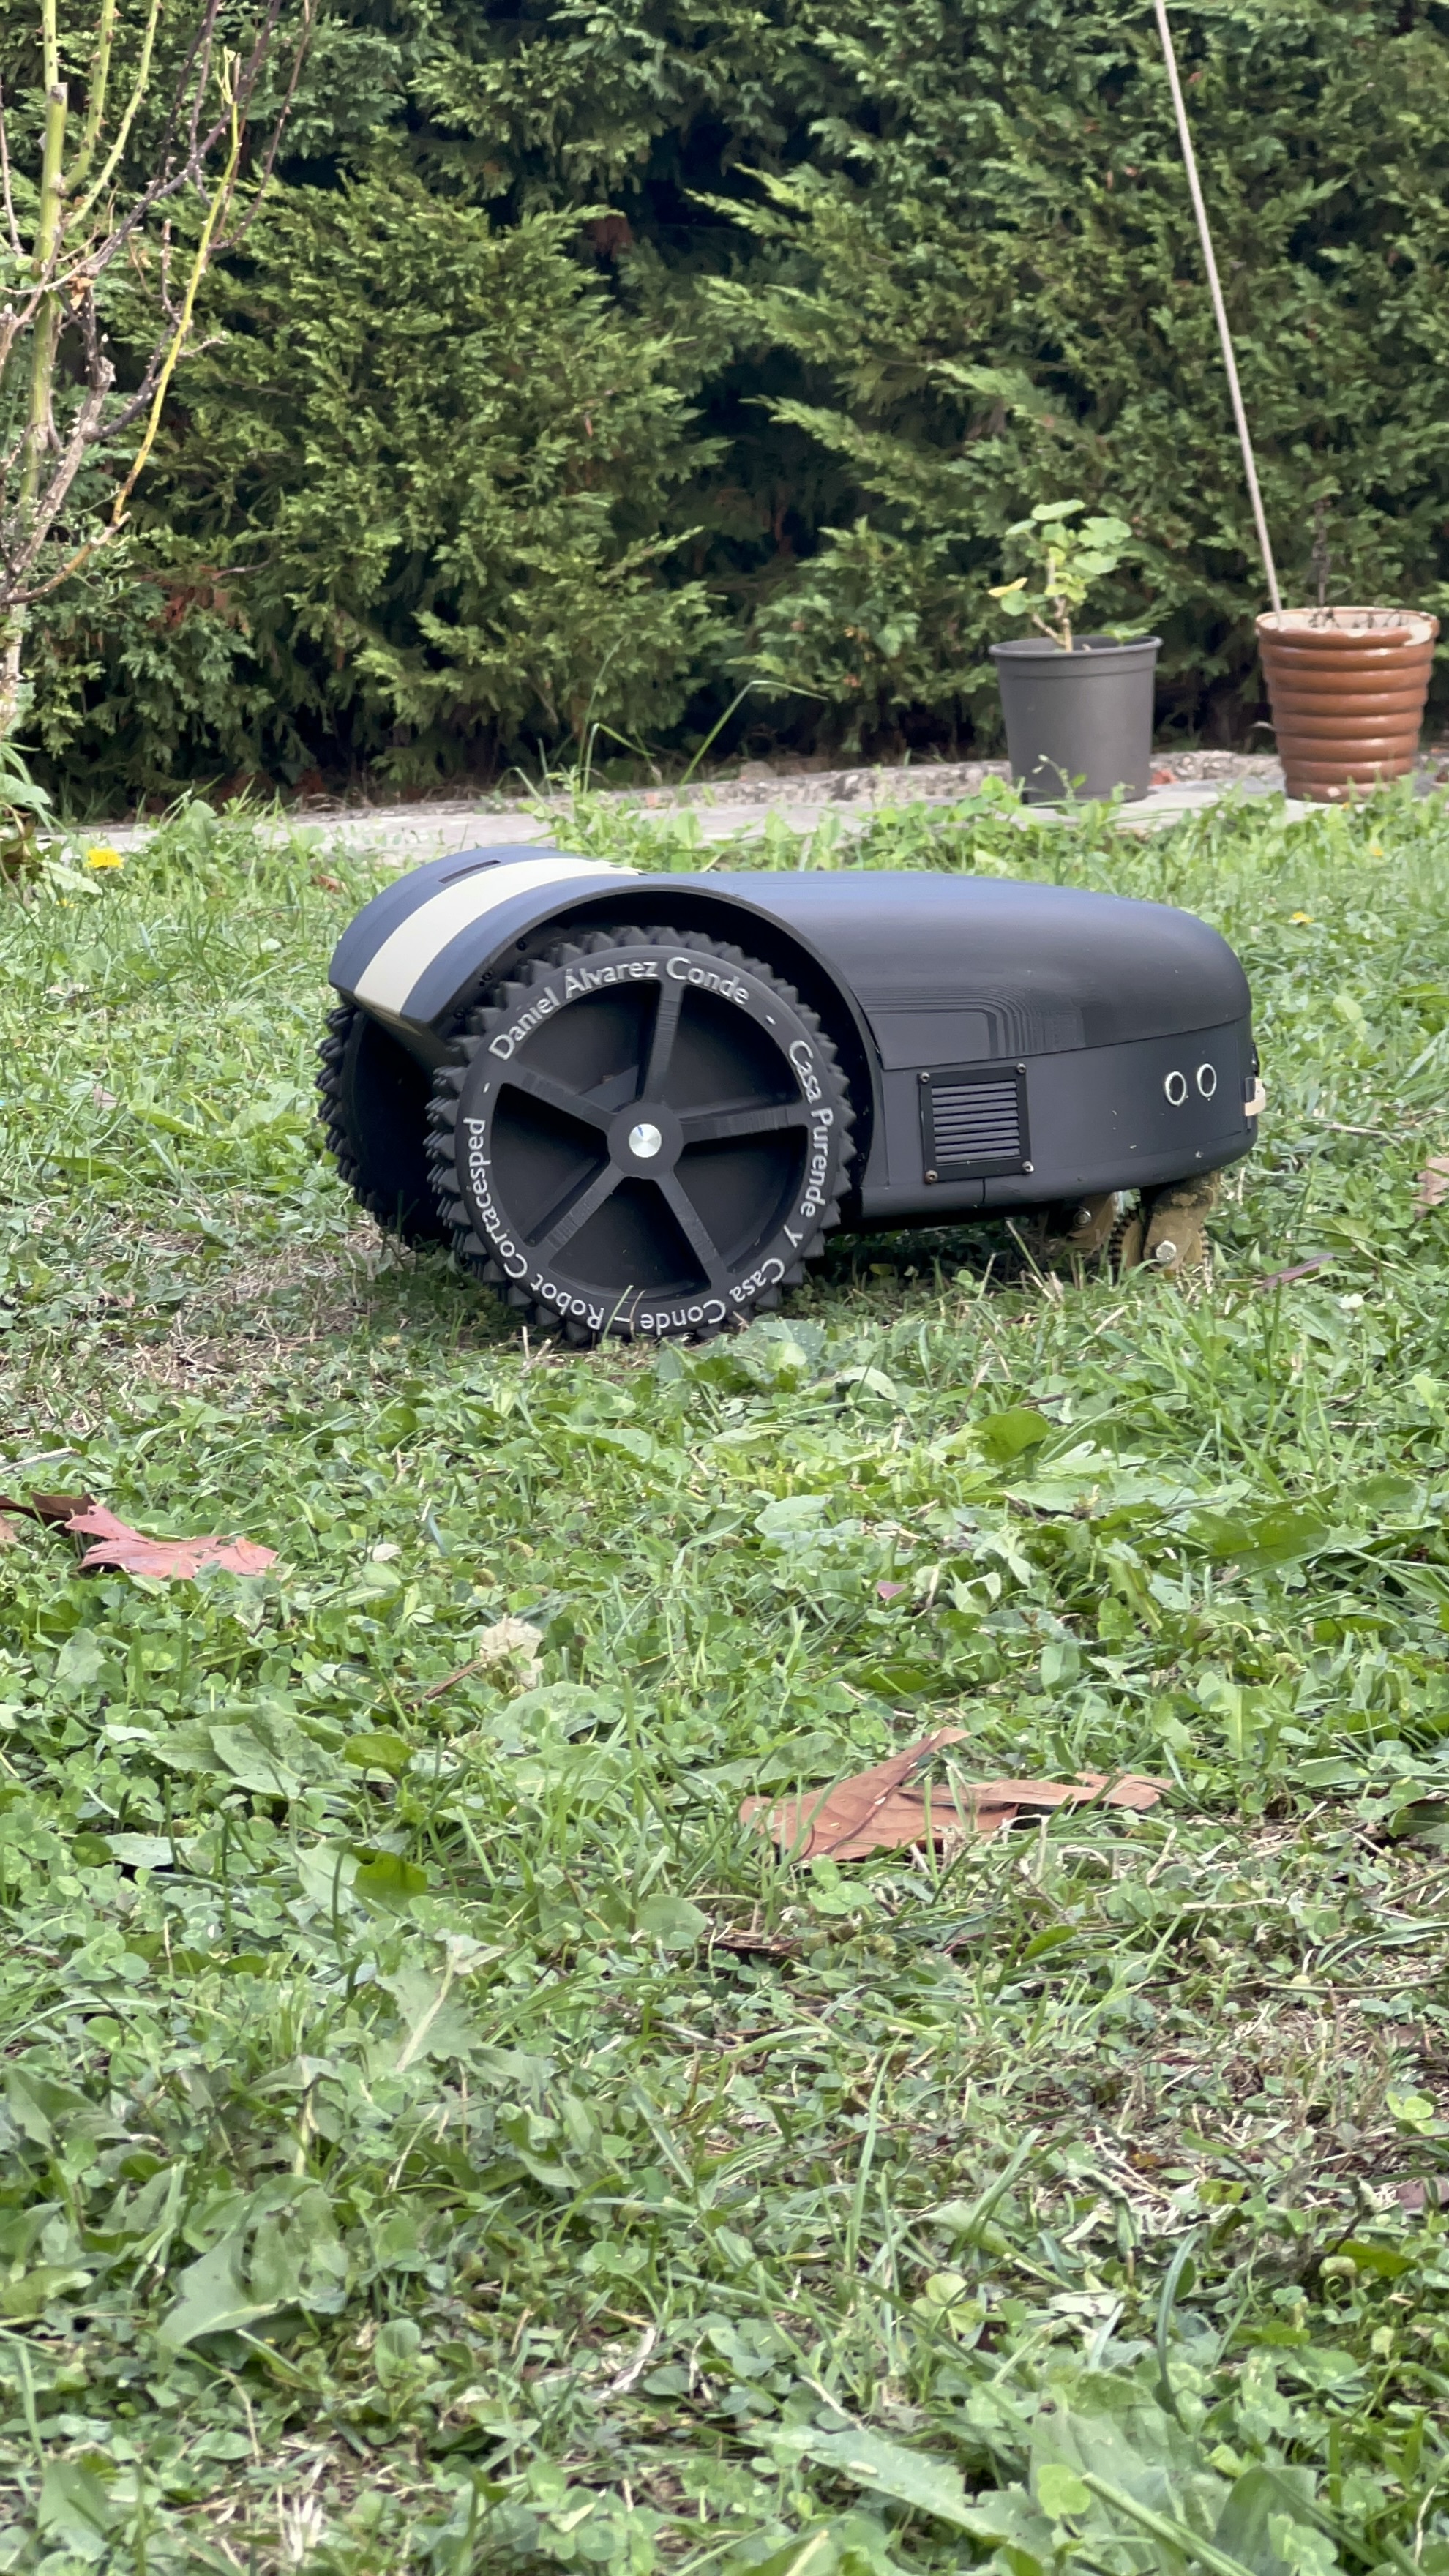
Autonomous robot mower built from the Rep_AL open-source base and turned into my own field-tested machine: 3D-printed structure, battery and power work, jumper-wire electronics replaced by a custom PCB, and a heavily reworked firmware stack for the Mega, TFT, EEPROM, serial links, sonar array, blade recovery, boundary-wire tracking, and return-to-dock behavior.

  • Built from the Rep_AL open-source base, then assembled, wired, debugged, translated, and adapted into my own working mower.
  • Chronological build from 3D-printed structure and battery packaging to real mowing tests and return-to-dock behavior.
  • Custom PCB replaced the fragile jumper-wire motherboard and made hardware failures easier to diagnose.
Arduino Mega 2560Arduino NanoESP32 (Wi-Fi AP)NodeMCU / Blynk 2.0Custom PCBBoundary wire transmitterSonar sensorsTFT touch displayDC-DC 12V→5V converterOscilloscope
View project
Tactile Vision System for Reading Through Vibration
Research
2026

Tactile Vision System for Reading Through Vibration

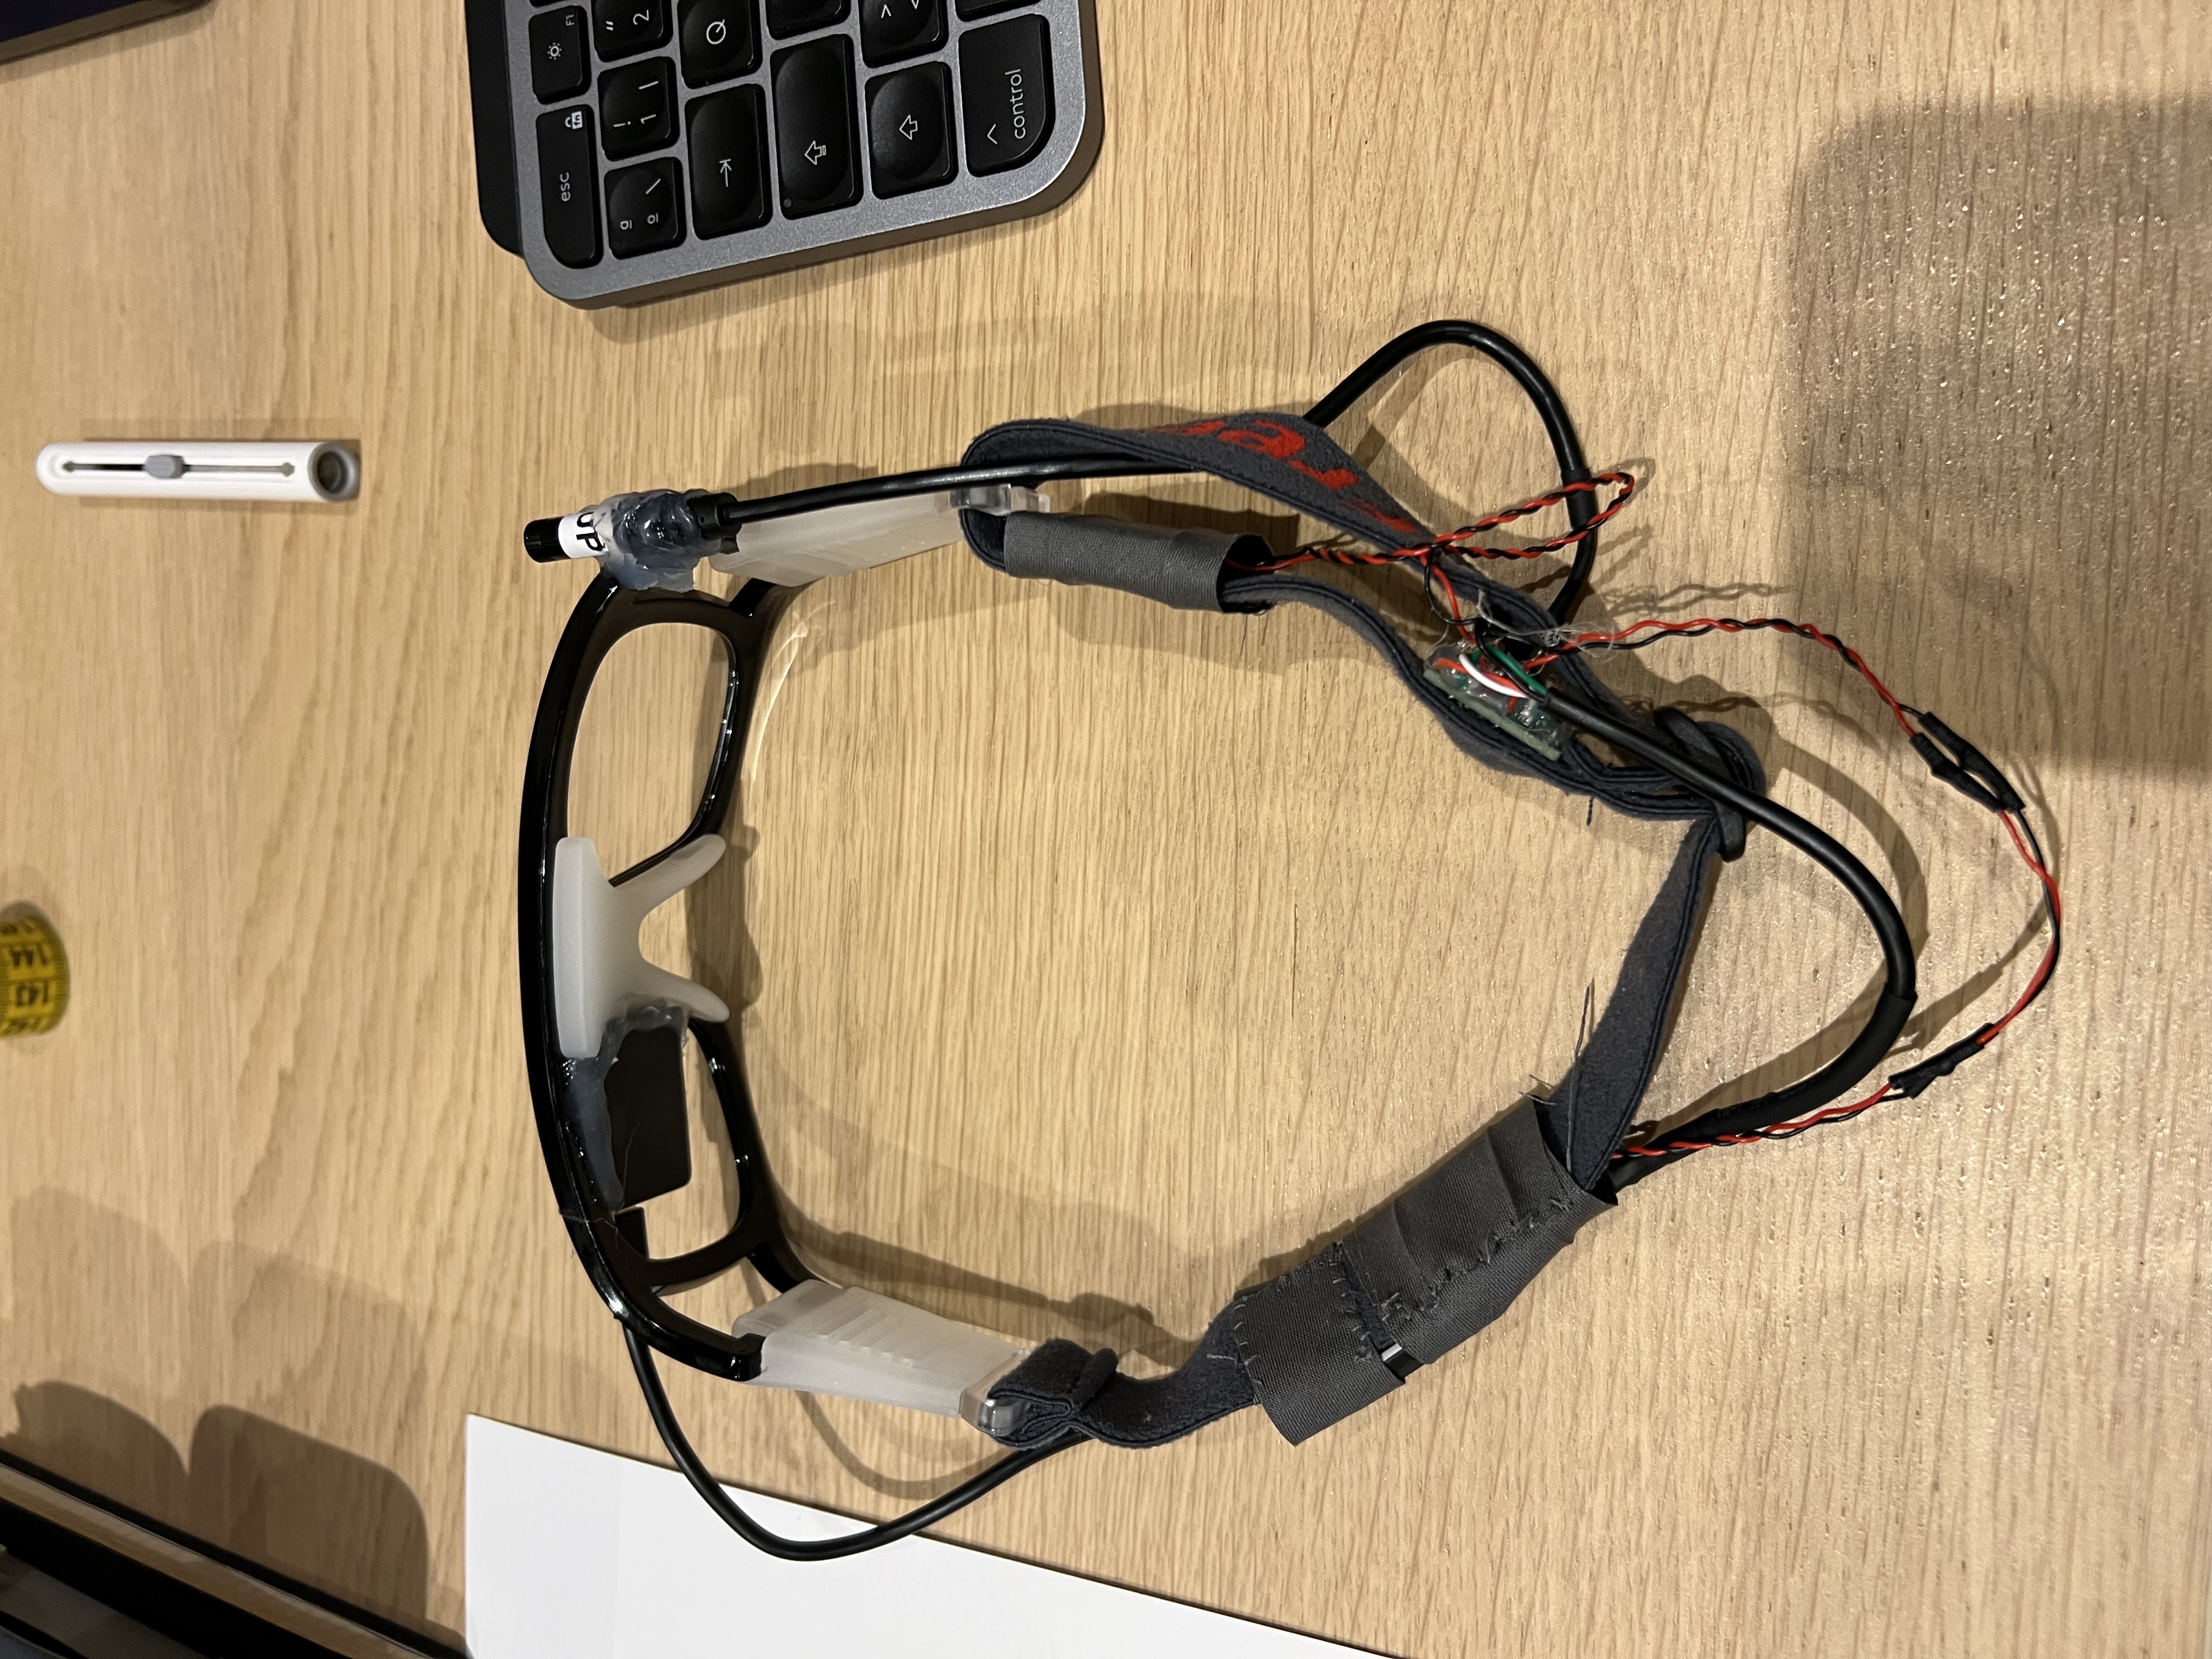
This project is the next engineering phase of my wearable tactile vision system for visually impaired children. The goal is no longer limited to basic object awareness. Instead, the system is designed to recognize clear, meaningful shapes — such as hearts, flowers, stars, and eventually letters — and translate them into vibration patterns that the child can learn to interpret. In the long term, this is aimed at supporting early symbol recognition and, potentially, the first steps toward reading through touch.

  • Complete hardware redesign from head-heavy glasses to a lightweight sports-style wearable.
  • Body-mounted computing unit to improve comfort and reduce strain on the child.
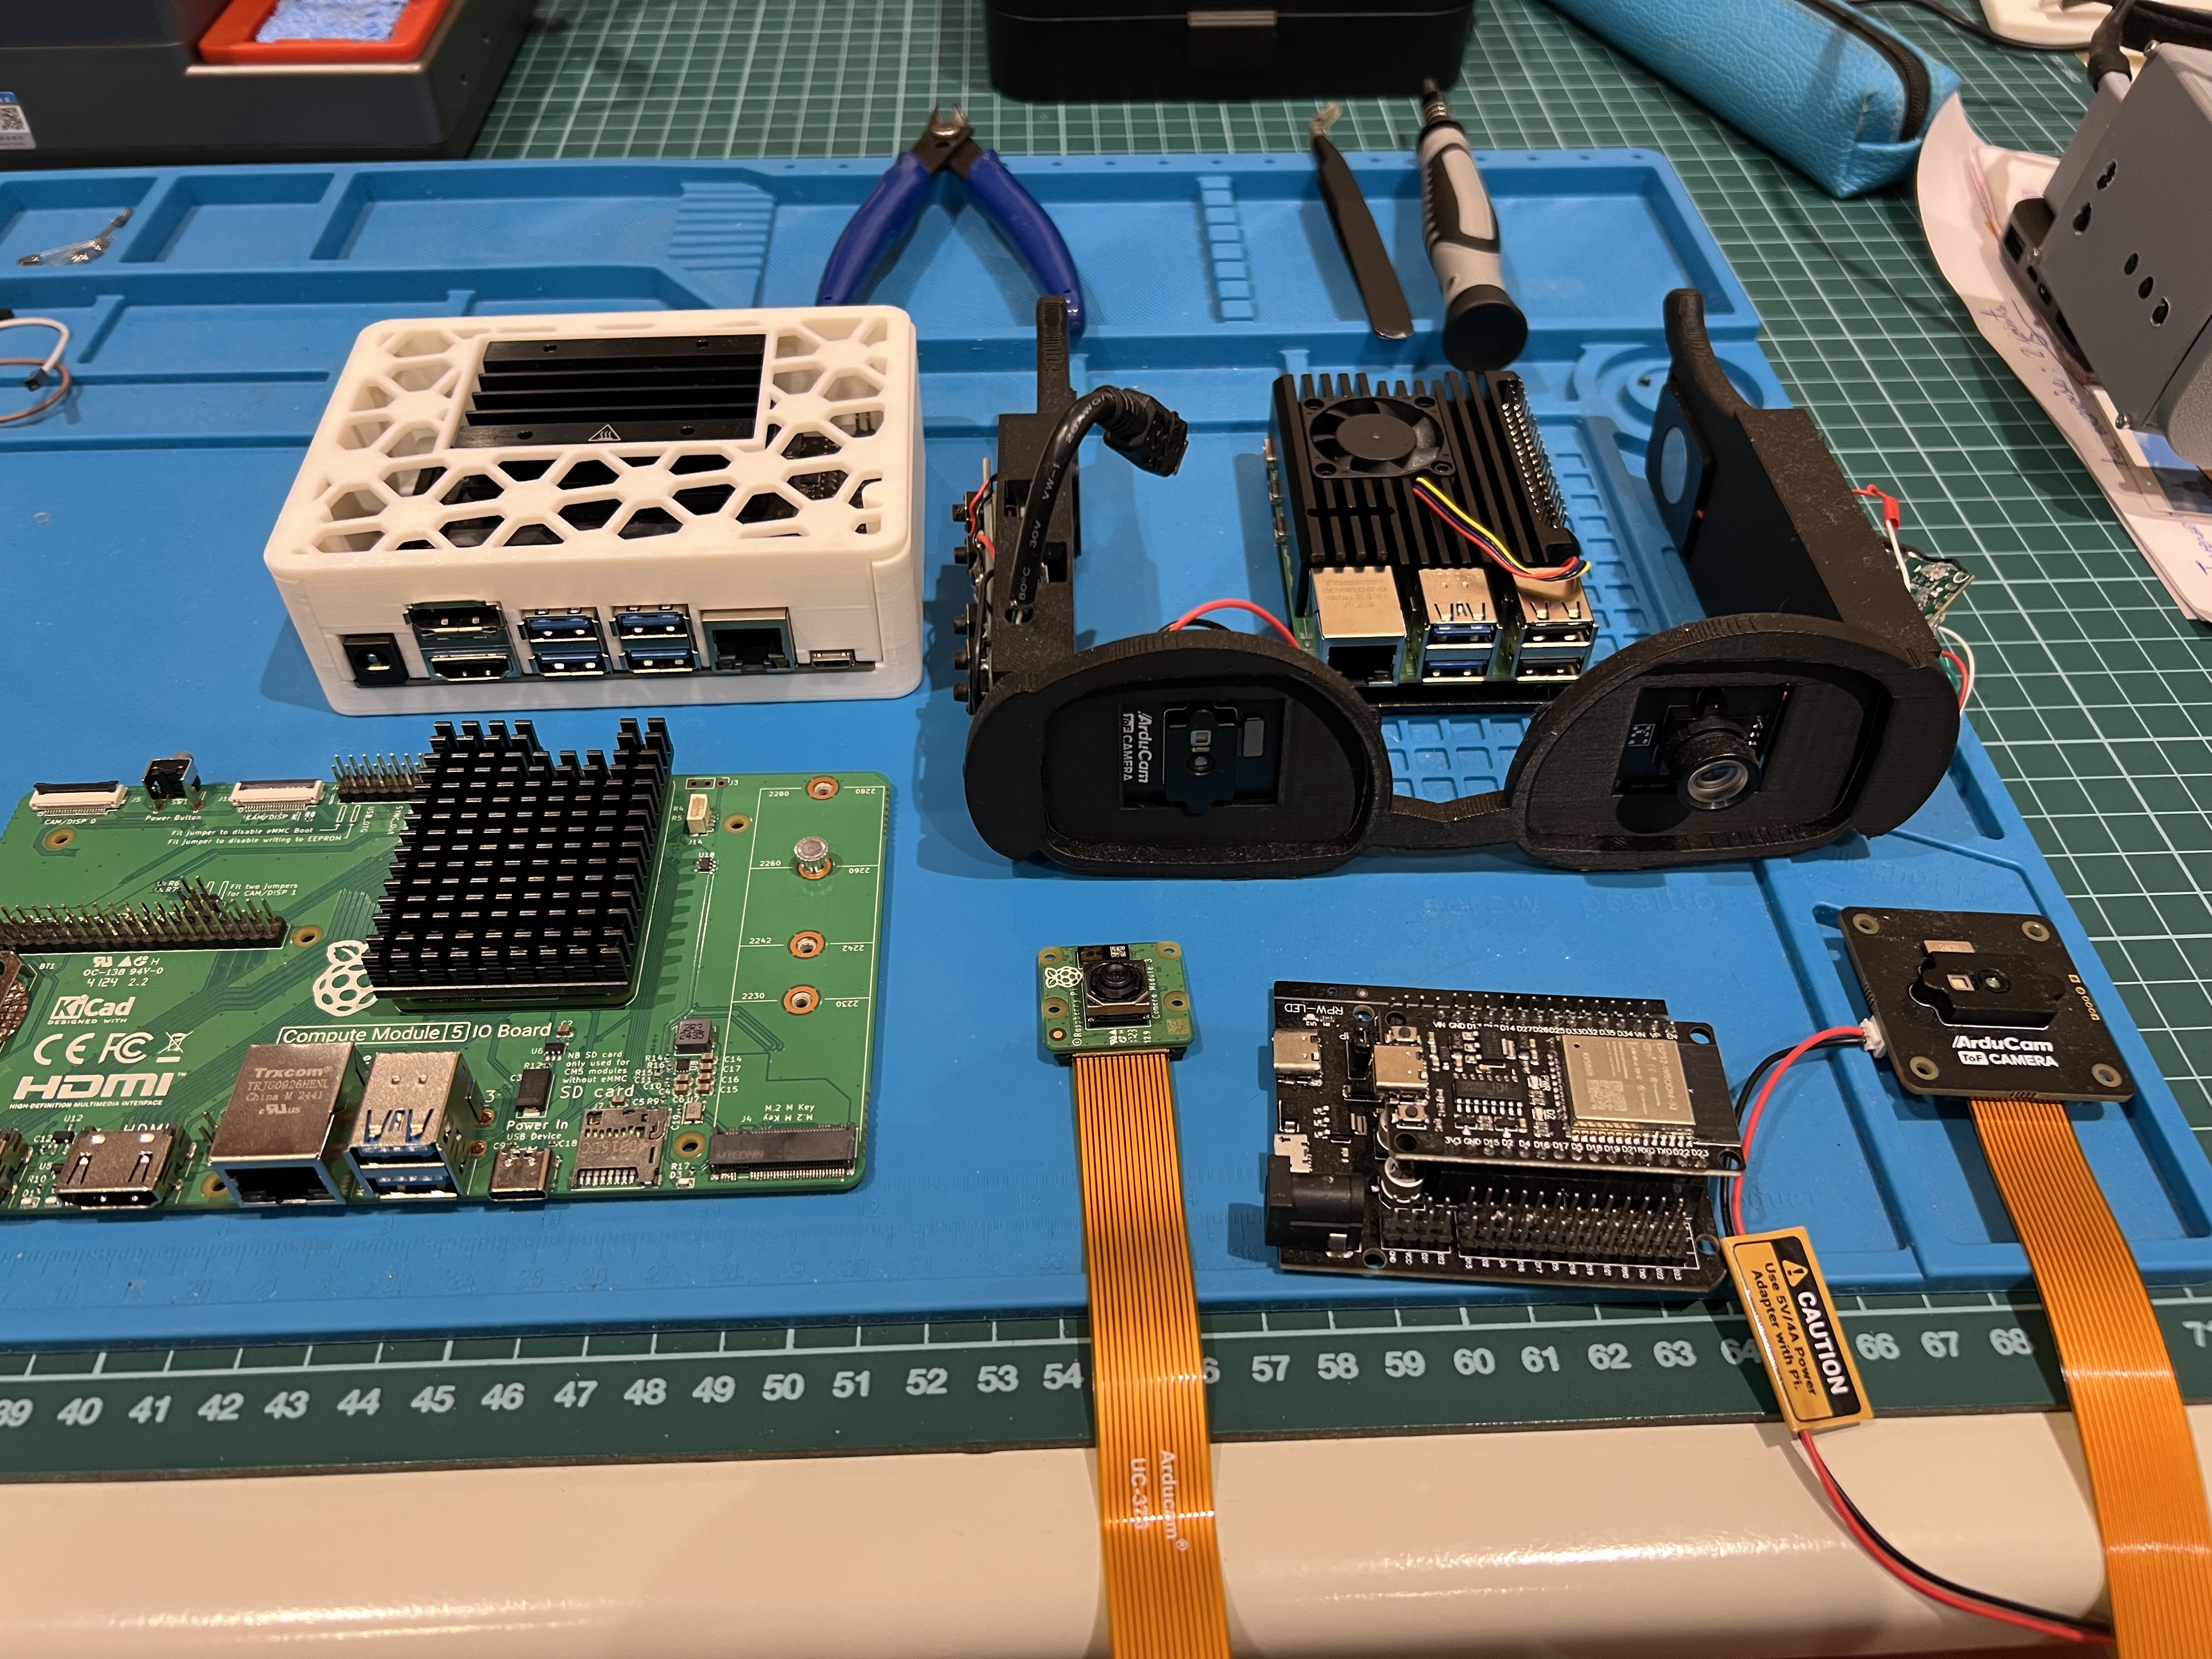
  • Raspberry Pi Compute Module 5 as the embedded AI and processing platform.
Raspberry Pi Compute Module 5Custom carrier boardCSI camera moduleI2C vibration matrixOpenCVLightweight CNN-based inferenceEdge AI pipeline3D-printed sports-style glasses
View project
A 3D-Printed Digital Stethoscope
Research
2025-11 to Present

A 3D-Printed Digital Stethoscope

A fully 3D-printed digital stethoscope designed to be accessible, repairable, and adaptable for real-world clinical feedback.

  • Portable prototype for respiratory follow-up research.
  • Designed with accessibility and repairability in mind.
  • Developed with clinical and research feedback.
3D printingEmbedded electronicsMobile health researchRespiratory audio analysis
View project
Mini Projects
2026-03

3D Space Mouse for Fusion 360

When I first considered learning 3D design, I accidentally discovered 3Dconnexion's SpaceMouse devices and loved the concept, but the price was hard to justify. So I looked into how these 3D mice work, found a low-cost DIY approximation, and built my own version with a 3D-printed mechanism and smoother firmware.

  • Uses the local MP4 demo as the primary project preview.
  • Keeps the local MP4 as the main preview while removing it from the vlog body.
  • Includes the Salim Benbouziyane video as a build reference.
Fusion 3603D space mouse prototypeCustom hardware inputMP4 demo capture
View project
Memory Game for the 6502 computer
Personal
2026-01 to 2026-02

Memory Game for the 6502 computer

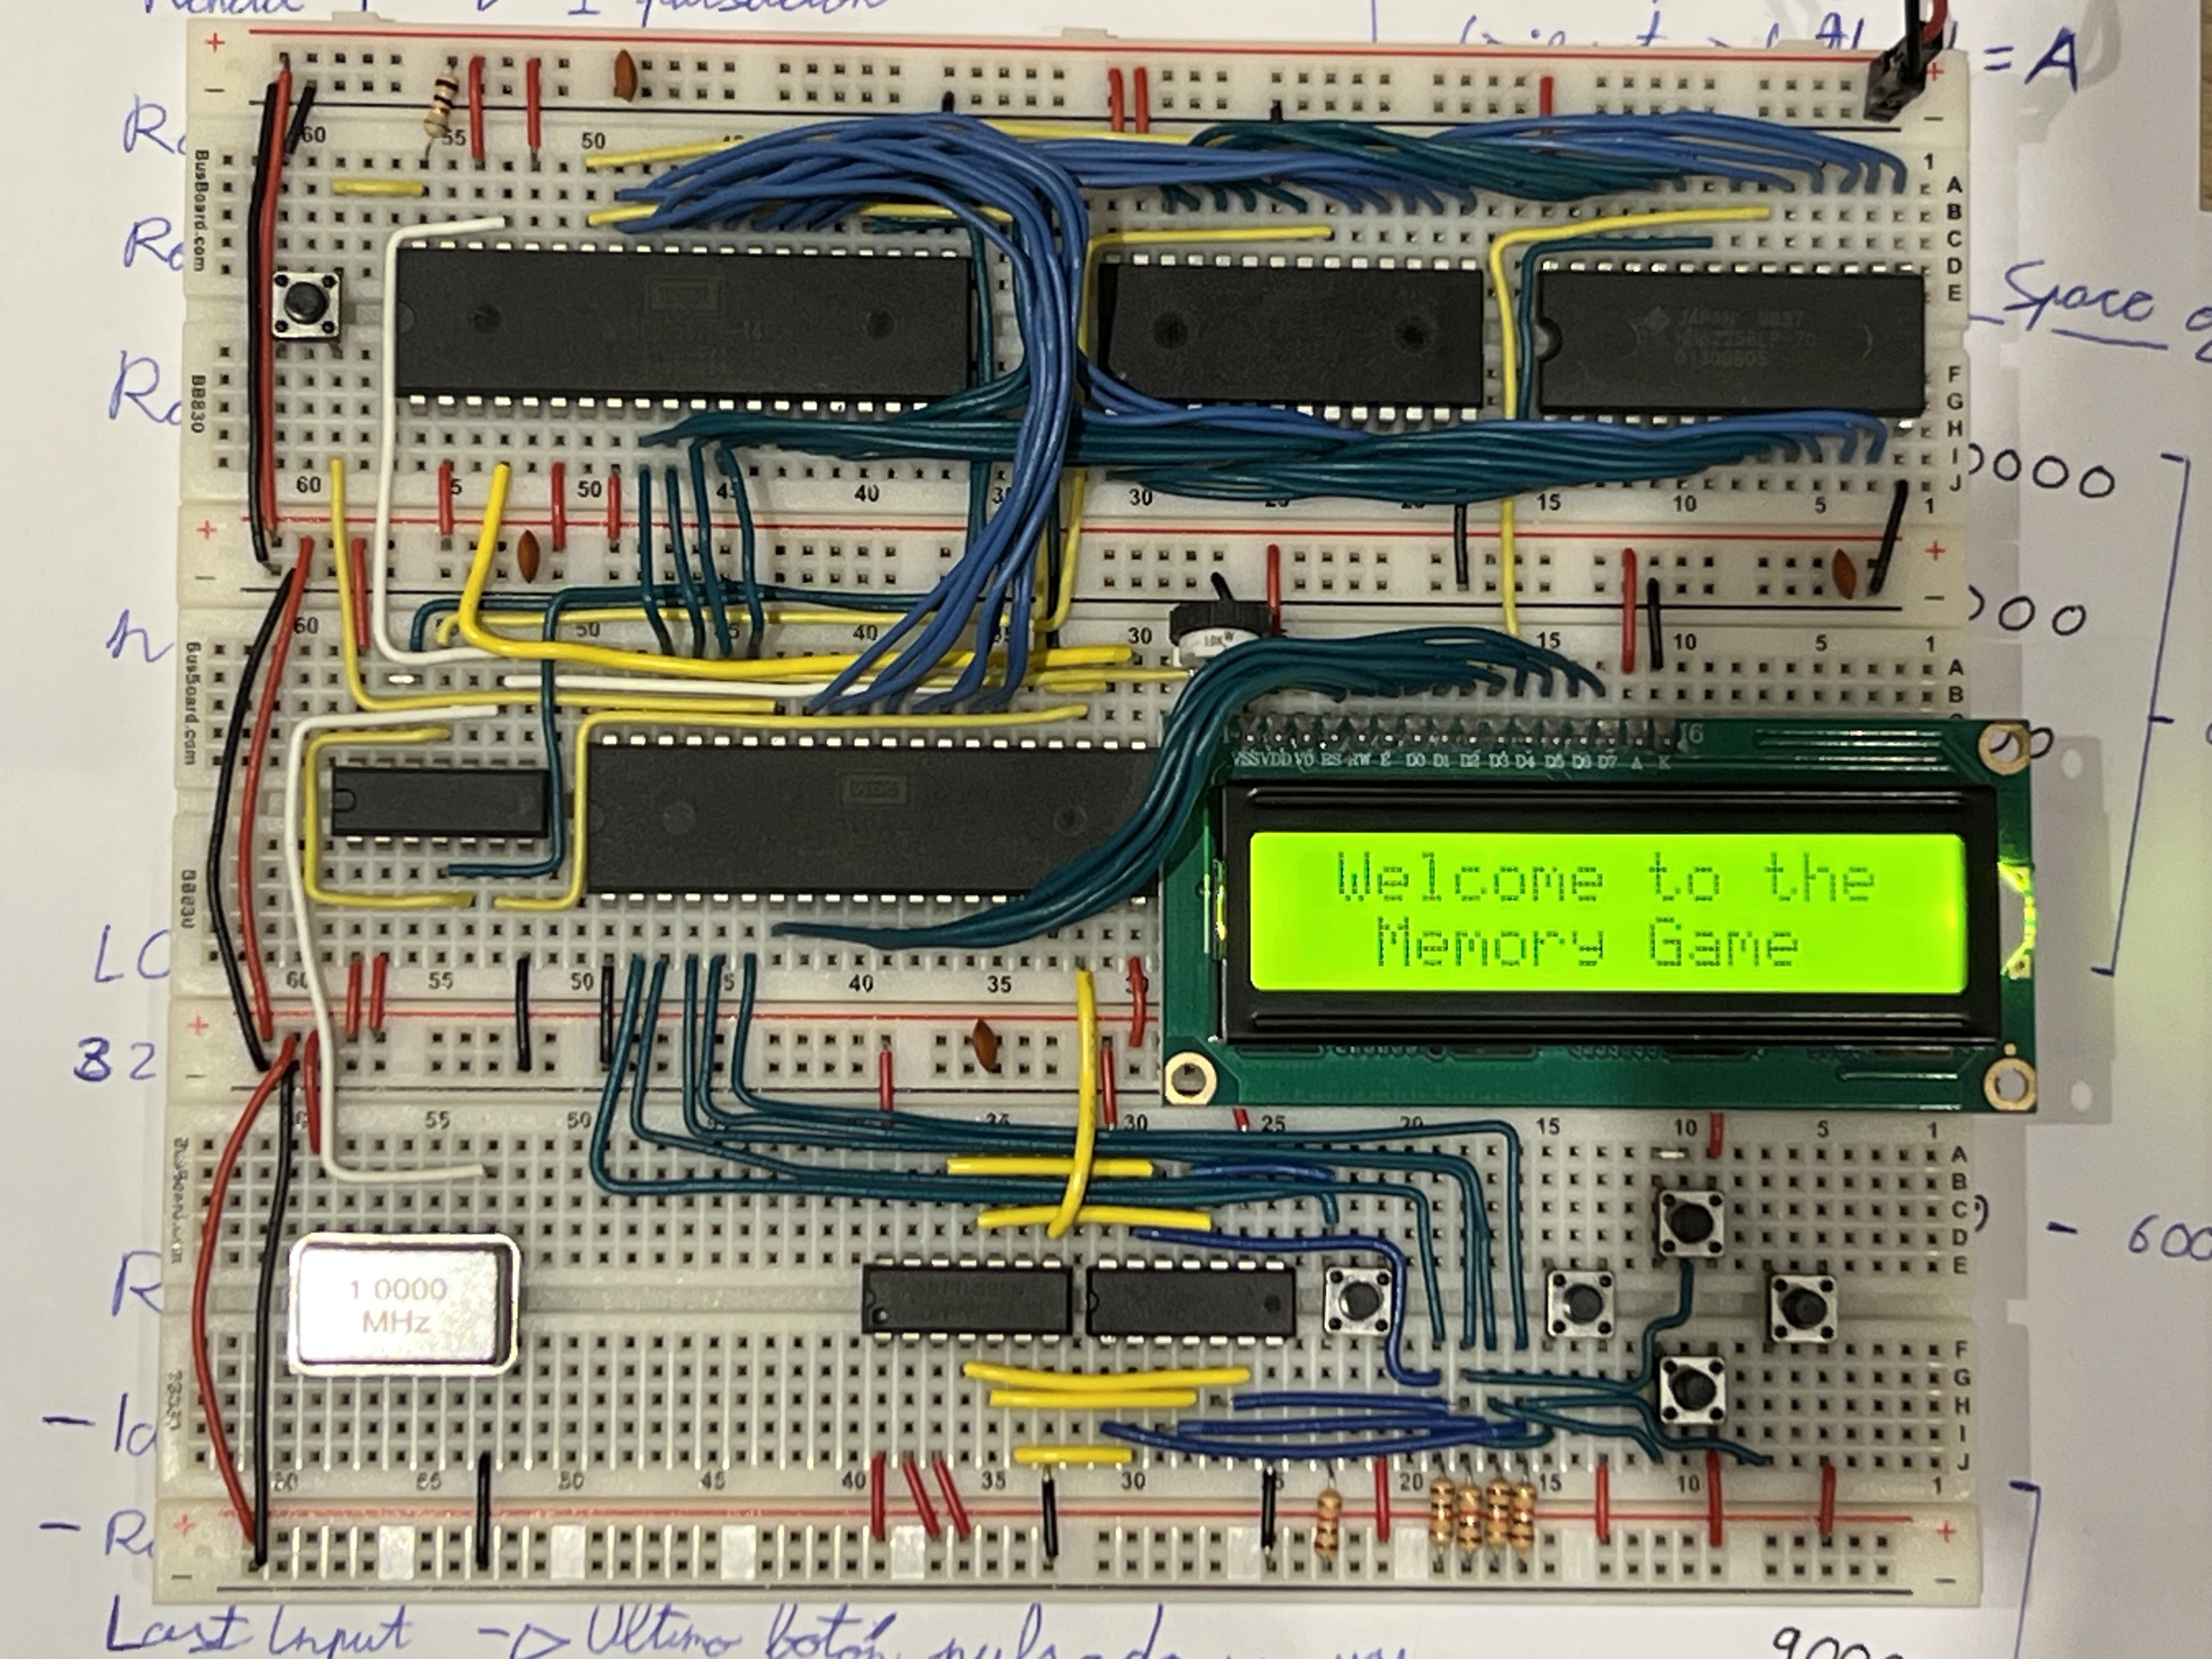
65C02/65C22-based Simon Says memory game in 6502 assembly with HD44780 LCD output. Implemented IRQ-driven button input through the VIA, a RAM-backed sequence buffer (up to 32 steps), and debouncing/validation logic inside a minimal ISR. Built the memory map and LCD driver routines (busy-flag polling, cursor control) to keep the game deterministic on real hardware.

    65C02 CPUWDC 65C22 VIAHD44780 16x2 LCD6502 assemblyBreadboard wiring
    View project
    Tactile Vision System for Mobility Assistance
    University
    2025

    Tactile Vision System for Mobility Assistance

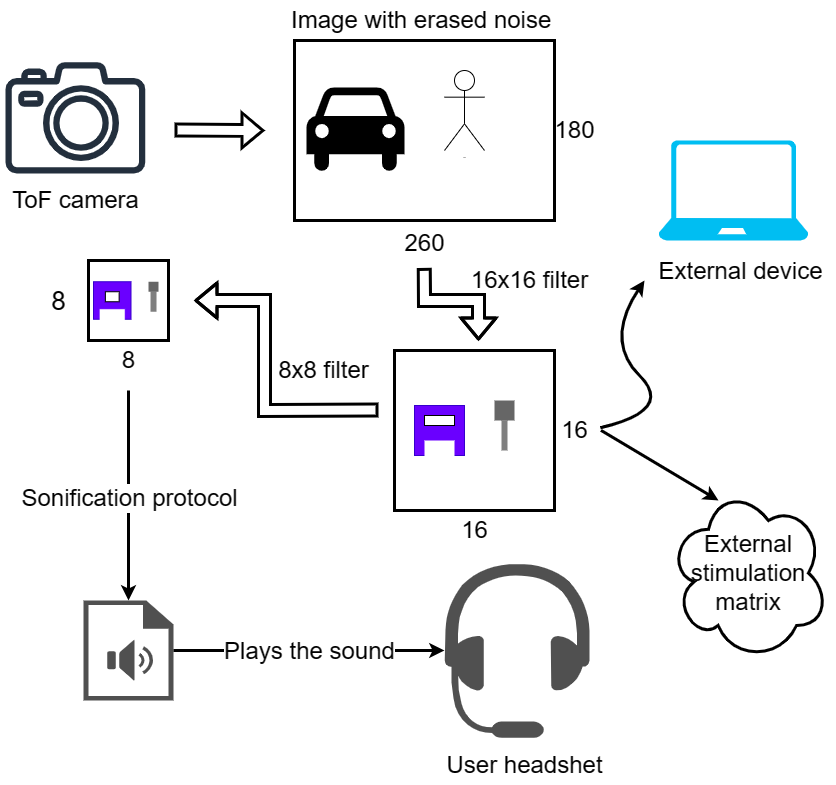
    A wearable sensory-substitution study that turns environmental depth into audio and vibration to explore how spatial information may be learned through touch.

    • Multimodal feedback: 16×16 haptic matrix + stereo sonification from a ToF depth camera.
    • Real-time pipeline with reduced 16×16 / 8×8 representations for tactile and audio cues.
    • Design targets focus on low cost, lightweight form factor, offline operation, and battery use.
    ToF depth cameraSingle-board computerEdge TPUOpenCVI2C3D-printed glassesVibration matrixSonification
    View project
    Why I Chose Robotics: The LeRobot SO-101
    Personal
    2026-01 to Present

    Why I Chose Robotics: The LeRobot SO-101

    Somewhere around the end of my Computer Engineering degree — honestly, even before that — I realized I didn’t want to spend my whole professional life building infrastructures and systems that, no matter how complex they are, always end up judging your work with a number on a screen. And yeah, that’s a bit of an unfair generalization: there are plenty of software engineering projects that are genuinely interesting, professionally demanding, and deeply rewarding. But it wasn’t what I was looking for.

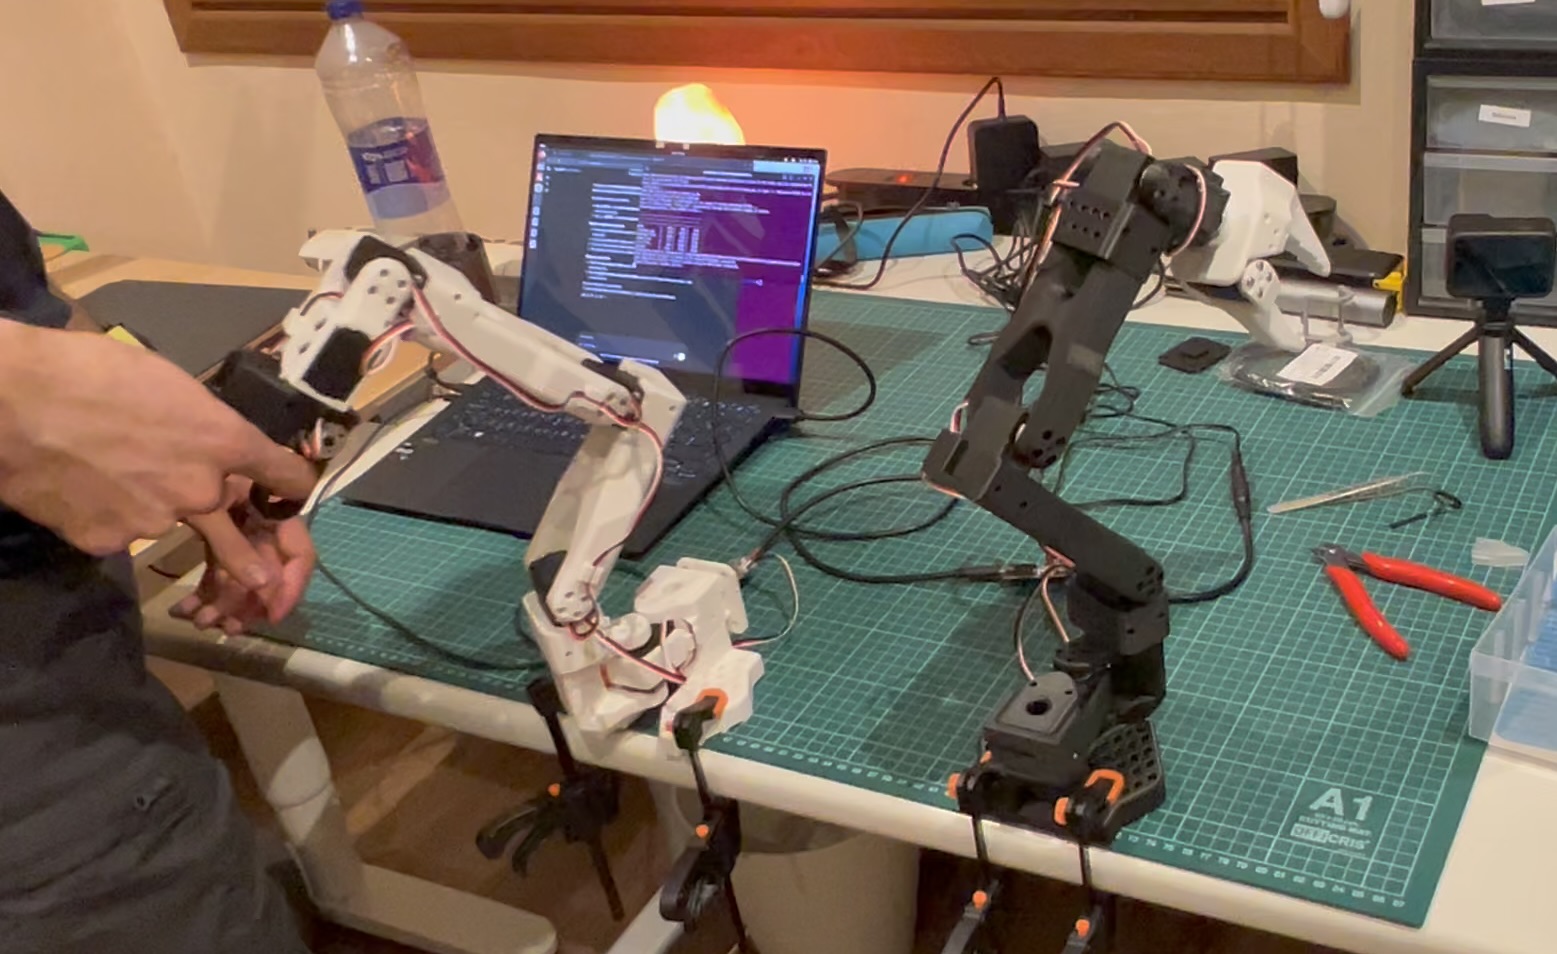
    • Leader + follower 6-DoF arms for imitation learning.
    • Mixed gear ratios for easy hand guidance and higher follower torque.
    • Vision-assisted manipulation pipeline in development.
    SO-ARM101 platformFeetech STS3215 servos3D-printed partsBus servo controlImitation learningComputer vision (in progress)
    View project
    Opening the Black Box: A 6502 Breadboard Computer
    Personal
    2022-07 to 2024-01

    Opening the Black Box: A 6502 Breadboard Computer

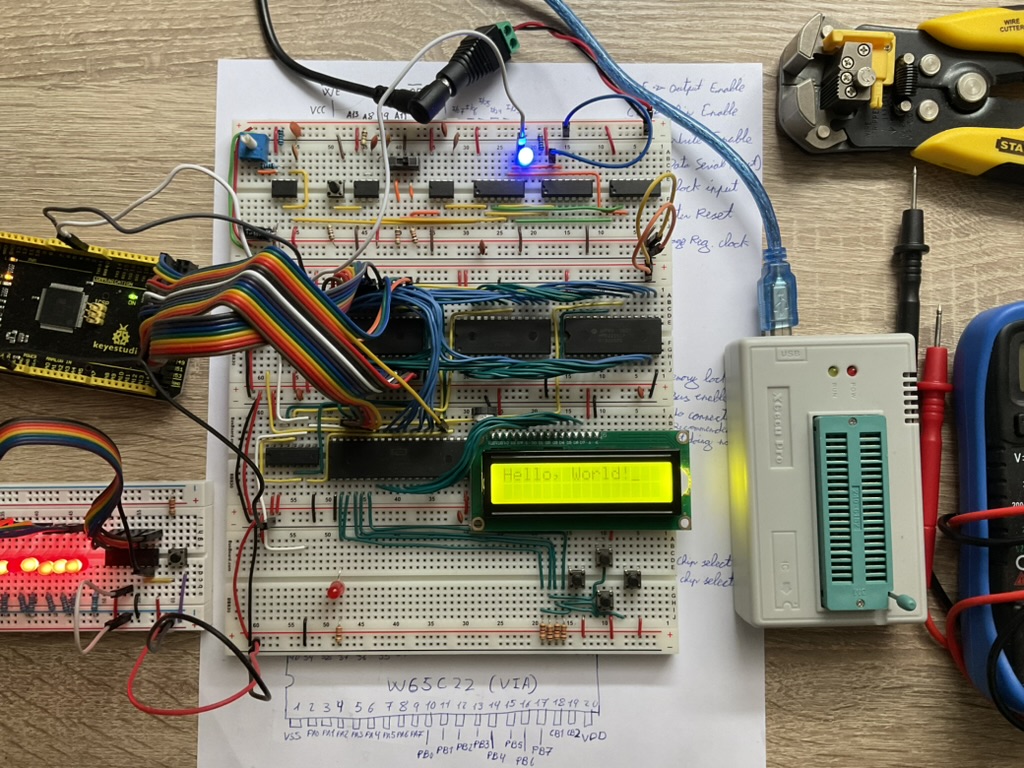
    Built a working 6502 breadboard computer on protoboards to display text on an LCD screen.

    • Built a working 6502 computer on breadboards.
    • EEPROM programmable with an LCD screen.
    6502 microprocessorArduino MegaEEPROMDatasheetsBreadboard wiring
    View project
    From Binary Counters to a VGA Signal
    Personal
    2022-07 to 2024-01

    From Binary Counters to a VGA Signal

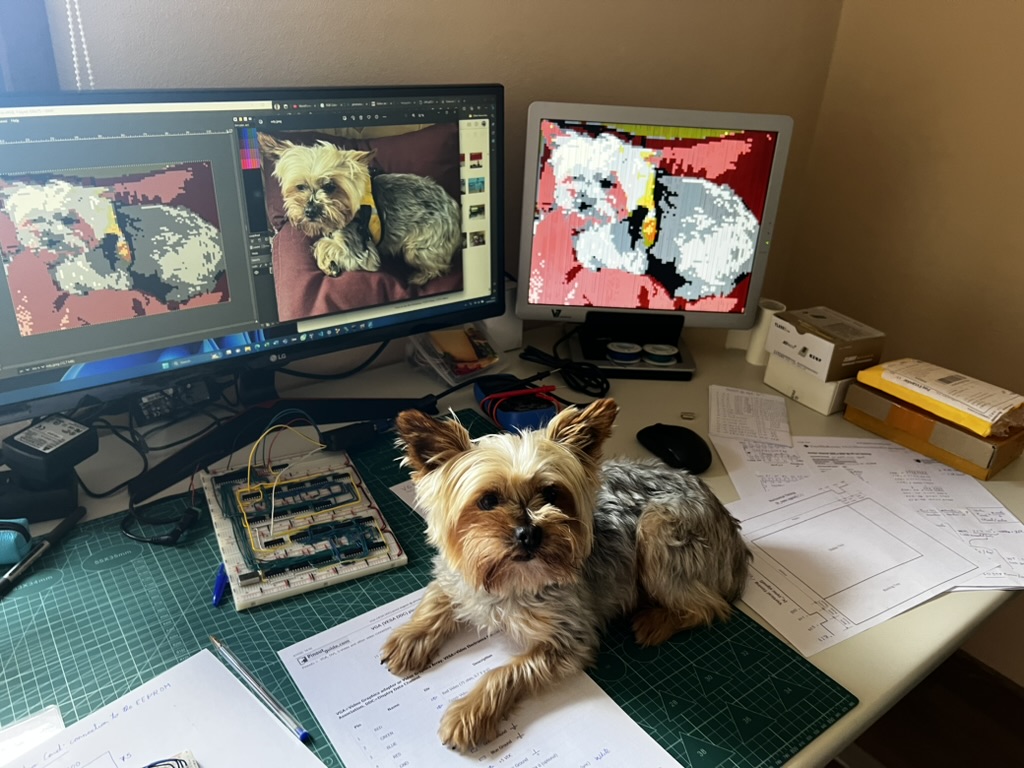
    Designed VGA timing (HSYNC/VSYNC, porches) with counters and discrete logic. EEPROM-backed image data (addressing + streaming). Resistor DAC for analog RGB levels (0–0.7 V into 75 Ω). Breadboard wiring, debugging, and datasheet-driven verification.

    • Designed VGA timing (HSYNC/VSYNC, porches) with counters and discrete logic.
    • EEPROM-backed image data (addressing + streaming).
    • Resistor DAC for analog RGB levels (0–0.7 V into 75 Ω).
    EEPROMVGA protocolDatasheetsBreadboard wiringResistor DAC
    View project